Looking for the latest information on 07 Cartesian Path Planning? We've compiled comprehensive data, records, and insights about 07 Cartesian Path Planning.
Important Facts
Explore the primary sources for 07 Cartesian Path Planning.
Latest News
Stay updated on 07 Cartesian Path Planning's latest milestones.
MoveIt Google Summer of Code: Cartesian Motion Planning
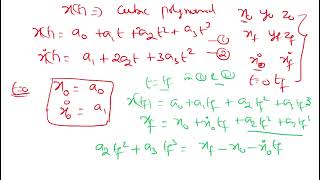
Lecture 21: Trajectory Planning
[ROS-MoveIt] Cartesian path planning with UR5
Path Planning for Robotics - Computerphile
Cartesian Space Trajectory Planning: Plotting the Path in the XY Plane, 20/11/2016
Descartes Cartesian Planning Improvements for Large Work Volumes
Steps Followed in Cartesian Space Trajectory Planning and a Comparison with Joint Space, 13/12/2015
Trajectory Planning for Robot Manipulators
Cartesian path planning and execution with MoveIt!
MoveIt Circular path Planning using Cartesian Paths - ROS
Trajectory Planning in Joint Space and Cartesian Space, 6/12/2105
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 22, 2026
Final Thoughts
For 2026, 07 Cartesian Path Planning remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
In this tutorial, you'll build a complete Jeroen de Maeyer, PhD student in robotics at KU Leuven in Belgium, presents his work on integrating constrained motion ... To access the translated content: 1. The translated content of this course is available in regional languages. For details please ... 이 비디오 정보: 나의 동영상 5. Need to get to your goal quickly? Ensure you ... Lights seeks to leverage Boost Graph Library to accelerate the computational performance of Sebastian Castro discusses technical concepts, practical tips, and software examples for motion The turtlebot detects the tool location and generates end effector trajectories based on a series of waypoints once the marker is in ... in this code we make the right end-effector go through a circular