Background to A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation
Looking for the latest information on A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation? We've researched comprehensive data, records, and insights about A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation.
Core Information
Explore the main sources for A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation.
Latest News
Stay updated on A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation's newest achievements.
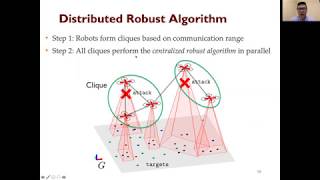
ICRA '20: Distributed Attack-Robust Submodular Maximization for Multi-Robot Planning
ICRA 2020: Representing Multi-Robot Structure ... for the Selection of Robot Teams
ICRA 2020 Presentation
Priority-based distributed coordination for heterogeneous multi-robot systems
A fully autonomous aerial multi-robot system for power tower inspection tasks
OmniSLAM: Omnidirectional Localization and Dense Mapping, ICRA 2020
WAFR 2020: Approximation Algorithm for Multi-Robot Coverage
ICRA 2020 Locomanipulation Presentation Final
[ICRA 2023] LIO-SEGMOT - Presentation Video
Presentation IROS 2020 - Multi-robot Coordination with Agent-Server Architecture
Distributed Multi-Robot Active-Sensing of a Diffusive Source
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: October 22, 2026
Final Thoughts
For 2026, A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
The paper is available at infoscience.epfl.ch/record/279927 Abstract: Finding sources of airborne chemicals with mobile ... Spotlight Talk for 'Efficient Large-Scale Caelan R. Garrett, Chris Paxton, Tomás Lozano-Pérez, Leslie P. Kaelbling, Dieter Fox. Online Replanning in Belief Space for ... Here we show the basic concepts and results described in the paper: Michele Cecchi, Matteo Paiano, Anna Mannucci, ... ABSTRACT: Inspection of power line infrastructures must be periodically conducted by electric companies in order to ensure ... Supplementary video for the paper: Changhee Won*, Hochang Seok*, Zhaopeng Cui, Marc Pollefeys, and Jongwoo Lim ... Pointer to paper: arxiv.org/pdf/1909.08804.pdf Citation: S. Jorgensen, M. Vedantam, R. Gupta, H. Cappel, and L. Sentis, ... Abstract - In this work, we present a This paper considers the problem of coordinating a group of mobile
A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation.pdf
What is the most accurate information about A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation.
Why is A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation trending right now?
Interest in A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation updated?
We regularly update our database with the latest information, media, and analysis related to A Distributed Source Term Estimation Algorithm For Multi Robot Systems Icra 2020 Presentation.