Introduction on Attitude Control With Factor Graphs
Looking for the latest information on Attitude Control With Factor Graphs? We've researched comprehensive data, records, and insights about Attitude Control With Factor Graphs.
Main Features
Explore the primary sources for Attitude Control With Factor Graphs.
Latest News
Stay updated on Attitude Control With Factor Graphs's latest milestones.
Factor graph optimization for GNSS/INS integration: A comparison with the extended Kalman filter
Part 1: review of factor graphs
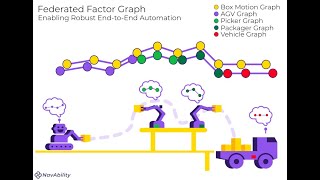
Tutorial 1, Basics of Factor Graphs, Walk Through
RI Seminar: Michael Kaess: Factor Graphs for Robot Perception
Factor Graphs for Navigation Applications: A Tutorial
Integrity-Constrained Factor Graph Optimization for GNSS Positioning in Urban Canyons
CMU RI Ph.D. Defense: Learning in Factor Graphs and Robot Manipulation
Frank Dellaert | Factor Graphs for Perception and Action | Tartan SLAM Series
Factor Graphs + TagSLAM For Efficient Map and Pose Optimization
Factor Graphs for Flexible Inference in Robotics and Vision | Frank Dellaert | Robotics@MIT
Factor graphs [4/5]: Applications to Engineering
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 21, 2026
Future Outlook
For 2026, Attitude Control With Factor Graphs remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
MIT - December 3, 2021 Frank Dellaert " For more information about Stanford's Artificial Intelligence professional and graduate programs, visit: stanford.io/2ZmzIQT ... By Weisong Wen, Tim Pfeifer, Xiwei Bai, Li-Ta Hsu Welcome to the NavAbility tutorial on ri.cmu.edu/event/ri-seminar-michael-kaess-cmu-2018-09-21/ Michael Kaess Assistant Research Professor Robotics ... Video abstract for paper published in NAVIGATION: Journal of the Institute of Navigation, Volume 71 Number 3. For full paper, or ... Title Learning and Inference in Presentation by Frank Dellaert titled, " How do robots really know where they are — not just guess? In this video, we dive deep into the world of