Mobile Robot Using the Bug2 Algorithm in Gazebo/ROS2
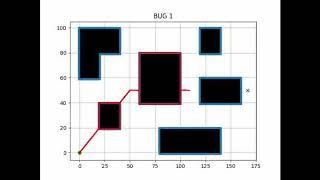
BUG2 Implementationon a Turtlebot
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 18, 2026
Future Outlook
For 2026, Bug2 Algorithm In Ros remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Call the line from the starting point to the goal the m-line 1) head toward goal on the m-line 2) if an obstacle is in the way, it ... Github github.com/KirillGordievich/bug_algorithms_gazebo. Book : Choset, H., Lynch, K. M., Hutchinson, S., Kantor, G., Burgard, W., Kavraki, L., & Thrun, S. (2005). Principles of Robot Motion: ... This video shows a simulated robot I developed in Gazebo and ROS2 that uses the