Looking for the latest information on Dynamic Potential Field Exploration? We've compiled comprehensive data, records, and insights about Dynamic Potential Field Exploration.
Main Features
Explore the main sources for Dynamic Potential Field Exploration.
History
Stay updated on Dynamic Potential Field Exploration's newest achievements.
Dynamic Path Replanning for the Parrot AR Drone Using a Potential Field Path Planner
Dynamic potential field generation using movement prediction
Advanced Artificial Potential Field for Safe and Efficient Local Path Planning
Obstacle Avoidance using Potential Field in Mapless Navigation - ODE simulation
Predictive Artificial Potential Field algorithm - energy-efficient local path planning algorithm
Potential Field Methods(Part-1): Lecture-14
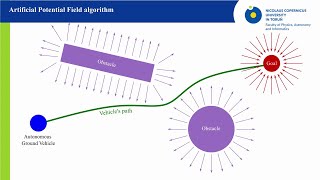
Robot Motion Planning - Artificial Potential Field Method
Potential Field-based Path Planning for Emergency Collision Avoidance with Clothoid Curve Tracking
Implementing A* algorithm | Artificial Potential Field (APF) method
Motion Planning using Path Guidance and a Artificial Potential Field
Artificial Potential Field for UR5e
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Final Thoughts
For 2026, Dynamic Potential Field Exploration remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
For my Guidance, Navigation and Control course. This work presents an integrated approach that combines trajectory optimization and Artificial My master thesis project at Simón Bolívar University in Venezuela. Real time robot navigation using The experimental and simulation verification of the proposed Advanced Artificial A brief presentation of the Predictive Artificial Subject: Mechanical Engineering and Science Course: Robot Motion Planning. Researched in Hanyang University A novel model curve fitting method combined with the Implementing A* algorithm | Artificial Avoidance of hundreds of moving obstacles using a path pre-computed to be free of collision with static obstacles to guide a ... We use the APF algorithm for manipulators motion planning in Gazebo.