Looking for the latest information on Graph Slam Demonstration? We've researched comprehensive data, records, and insights about Graph Slam Demonstration.
Core Information
Explore the main sources for Graph Slam Demonstration.
Recent Updates
Stay updated on Graph Slam Demonstration's newest achievements.
Understanding SLAM Using Pose Graph Optimization | Autonomous Navigation, Part 3
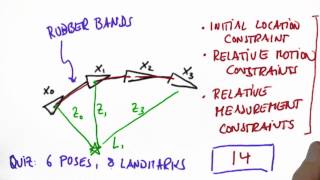
Graph-Based SLAM with Landmarks (Cyrill Stachniss)
Radar-Inertial ICP-based Pose Graph SLAM
SLAM - 5 Minutes with Cyrill
graphslam-engine - execute graphSLAM in MRPT
graph-slam demo: Loading a raw graph file vs. its Dijkstra tree global estimation:
Graph SLAM Solution - Artificial Intelligence for Robotics
Graph SLAM with occupancy grid - ISAM FLIRT in ROS
srba: Constant-time relative graph SLAM (2D demo)
ProSLAM: Graph SLAM from a Programmer's Perspective
[SymForce tutorial] Pose-graph SLAM Toy example
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Final Thoughts
For 2026, Graph Slam Demonstration remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
A plethora of localization solutions for different sensor modalities exists, yet robust sensing in degraded perception conditions ... The robot is estimating its pose and surrounding map simultaneously. The map is represented as a occupancy grid. Under the ... github.com/gisbi-kim/symforce-tutorials/blob/main/pgo/1_pgo3d_toy/pose_graph_opt_3d_toy.ipynb.