Looking for the latest information on Grasping Moving Object? We've compiled comprehensive data, records, and insights about Grasping Moving Object.
Important Facts
Explore the key sources for Grasping Moving Object.
Recent Updates
Stay updated on Grasping Moving Object's newest achievements.
Grasping and Stacking moving objects using Visual Servoing
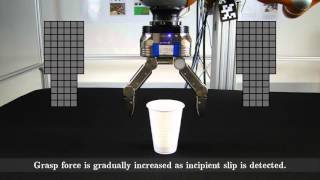
Adaptive Grasping with Slip Detection
GOAL: Generating 4D Whole-Body Motion for Hand-Object Grasping (CVPR'22)
Dynamic Grasping with Reachability and Motion Awareness
Moving Objects Grasping by an Assistive Robotic Arm (JACO) using Computer Vision
Generalizable Robotic Grasping of Unseen Objects
Robotic Grasping of Moving Objects by dynamic re-planning
Grasping 10 Objects mit SHAF
Simulation of robot dynamics for grasping and manipulation tasks
Improving reinforcement learning based moving object grasping with trajectory prediction
Dynamic Grasping with Reachability and Motion Awareness
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 16, 2026
Summary
For 2026, Grasping Moving Object remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Paper: merl.com/publications/docs/TR2023-118.pdf Abstract: We explore the dynamic For the first time, an algorithm trained only on synthetic data is able to beat a state-of-the-art network trained on real images for ... 1. Select a variety of materials from around the house 2. Use a plate, bowl or place mat as a 4 DOF Scara Arm. Simulation using ROS and Gazebo. github.com/nsabhari/Visual_Servoing. This video was created during the course of my master thesis "Evaluation of Tactile Sensors" at the Intelligent and Interactive ... We are glad to have Jingxi Xu from Columbia University to present his IROS 2021 paper. Abstract: Controlling the Robotic Arm Jaco from Kinova Robotics for catching Hardware demos from the project titled "Generalizable Robotic Beatriz León, Javier Felip, Higinio Marti and Antonio Morales Universitat Jaume I Castellòn, Spain In 2012 IEEE-RAS International ... This research tackles the robotic manipulation problem, aiming to develop an online, adaptive learning system for controlling ... 15-minute IROS 2021 video presentation for the paper: Dynamic