Looking for the latest information on Hexapod Locomotion Simulation? We've compiled comprehensive data, records, and insights about Hexapod Locomotion Simulation.
Important Facts
Explore the main sources for Hexapod Locomotion Simulation.
Developments
Stay updated on Hexapod Locomotion Simulation's latest milestones.
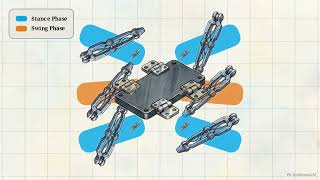
an Efficient Leg Design for Energy-efficient Locomotion for Hexapods
Hexapod Locomotion MapleSim (Tripod)
Hexapod walking simulation
Hexapod Locomotion MapleSim (Ripple Gait Top view)
Hexapod Locomotion MapleSim (Wave)
Hexapod Locomotion MapleSim (Ripple)
Kinematic Model of a Hexapod Robot with C-Legs
Simulation of Turning Gaits for Hexapod Walking Robot
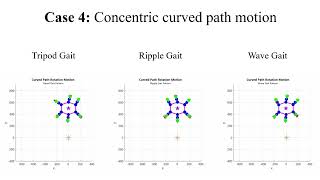
Hexapod Locomotion MapleSim (Curved Tripod gait)
Hexapod Simulator switching between locomotion patterns
MATLAB Simulink Hexapod Simulation
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Final Thoughts
For 2026, Hexapod Locomotion Simulation remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Hey, this project was done for the course - Computational Models of Motion for Character Animation and Robotics (ETH Zurich, ... Discover how gait analysis of a This video walks through a comprehensive Manoonpong and colleagues at SDU have proposed an efficient leg design for energy-efficient # The model is using inverse kinematics. (Tripod gait and rectangular body) (Ripple gait and circular body) The model is using inverse kinematics. Notice: As the robot moves forward it has the tendency of ... Part of my undergraduate thesis "Design and