Overview to Learning Deformable Object Manipulation Using Task Level Iterative Learning Control
Looking for the latest information on Learning Deformable Object Manipulation Using Task Level Iterative Learning Control? We've researched comprehensive data, records, and insights about Learning Deformable Object Manipulation Using Task Level Iterative Learning Control.
Main Features
Explore the primary sources for Learning Deformable Object Manipulation Using Task Level Iterative Learning Control.
Recent Updates
Stay updated on Learning Deformable Object Manipulation Using Task Level Iterative Learning Control's newest achievements.
SoftMimicGen: A Data Generation System for Scalable Robot Learning in Deformable Object Manipulation
Sim-to-Real Reinforcement Learning for Deformable Object Manipulation
Shape control tasks in deformable object manipulation - Miguel Aranda
Robotic manipulation of deformable rope-like objects using differentiable position-based dynamics
Learning to Manipulate Deformable Objects without Demonstrations
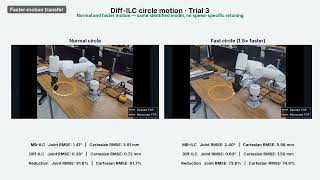
Diff-ILC: Differentiable Iterative Learning Control for Black-Box Position-Commanded Manipulators
Learning Latent Graph Dynamics for Deformable Object Manipulation
Learning Foresightful Dense Visual Affordance for Deformable Object Manipulation
Goal-Conditioned Model Simplification for Deformable Object Manipulation
Jeannette Bohg: Bridging Topology and Geometry in Deformable Object Manipulation
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 21, 2026
Conclusion
For 2026, Learning Deformable Object Manipulation Using Task Level Iterative Learning Control remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Learning Deformable Object Manipulation Using Task This paper presents a phase-conditioned, force-aware framework for robust Dmitry Berenson Assistant Professor Electrical Engineering & Computer Science Department, University of Michigan Friday, ... Project website: softmimicgen.github.io/ Large-scale robot datasets have facilitated the Authors: Jan Matas, Stephen James and Andrew Davidson, Department of Computing, Imperial College London Contact: ... Presentation video of "GenDOM: Generalizable One-shot Project website: cortx-lab.github.io/projects/differentiable-ilc/ Spotlight talk at 2nd Workshop on Representing and Prof. Jeannette Bohg Stanford University Title: Bridging Topology and Geometry in
Learning Deformable Object Manipulation Using Task Level Iterative Learning Control.pdf
What is the most accurate information about Learning Deformable Object Manipulation Using Task Level Iterative Learning Control?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Learning Deformable Object Manipulation Using Task Level Iterative Learning Control.
Why is Learning Deformable Object Manipulation Using Task Level Iterative Learning Control trending right now?
Interest in Learning Deformable Object Manipulation Using Task Level Iterative Learning Control has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Learning Deformable Object Manipulation Using Task Level Iterative Learning Control?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Learning Deformable Object Manipulation Using Task Level Iterative Learning Control updated?
We regularly update our database with the latest information, media, and analysis related to Learning Deformable Object Manipulation Using Task Level Iterative Learning Control.