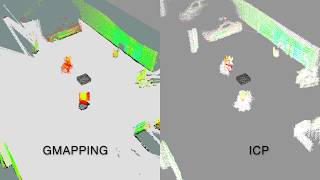
Overview of Mapping On Occupancy Grid With Iterative Closest Point Algorithm
Looking for the latest information on Mapping On Occupancy Grid With Iterative Closest Point Algorithm? We've compiled comprehensive data, records, and insights about Mapping On Occupancy Grid With Iterative Closest Point Algorithm.
Important Facts
Explore the primary sources for Mapping On Occupancy Grid With Iterative Closest Point Algorithm.
Recent Updates
Stay updated on Mapping On Occupancy Grid With Iterative Closest Point Algorithm's latest milestones.
Iterative Closest Point Algorithm
Occupancy Grid Maps (Cyrill Stachniss)
Iterative Closest Point Algorithm: Parallelized
MSR Course - 03 Occupancy Grid Mapping with Known Poses (Chebrolu)
Dealing with Occlusions using ICP (Iterative Closest Point) for Aerial Refueling
PointCloud to Occupancy Grid
Autonomous Indoor Navigation for an UGV: Mapping Visualisation for ICP and GMapping
Sparse Iterative Closest Point
Occupancy grid map algorithm running real-time on FPGA
CH12 SLAM for Robotics - Iterative Closest Point (ICP) Algorithm
Point-to-Plane and Generalized ICP - 5 Minutes with Cyrill
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Summary
For 2026, Mapping On Occupancy Grid With Iterative Closest Point Algorithm remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
ENLACE interns Yoatzin and Ziyun implemented You've scanned a room or object and now you have lots of discrete scans you want to fit together. Dr Mike Pound explains how ... Full code available at : github.com/vittorione94/ This is the parallelized version of the This video discusses analytical methods for minimizing the effects of boom occlusion on a partially visible receiver. The ... (coloured 3D point cloud) while driving along a 3m x 5m rectangle: Sofien Bouaziz, Andrea Tagliasacchi, Mark Pauly Symposium on Geometry Processing 2013 Abstract: Rigid registration of two ... In this Chapter: - Introduction and
Mapping On Occupancy Grid With Iterative Closest Point Algorithm.pdf
What is the most accurate information about Mapping On Occupancy Grid With Iterative Closest Point Algorithm?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Mapping On Occupancy Grid With Iterative Closest Point Algorithm.
Why is Mapping On Occupancy Grid With Iterative Closest Point Algorithm trending right now?
Interest in Mapping On Occupancy Grid With Iterative Closest Point Algorithm has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Mapping On Occupancy Grid With Iterative Closest Point Algorithm?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Mapping On Occupancy Grid With Iterative Closest Point Algorithm updated?
We regularly update our database with the latest information, media, and analysis related to Mapping On Occupancy Grid With Iterative Closest Point Algorithm.