Looking for the latest information on Me132b Bug 2 Algorithm On Turtlebot? We've researched comprehensive data, records, and insights about Me132b Bug 2 Algorithm On Turtlebot.
Main Features
Explore the key sources for Me132b Bug 2 Algorithm On Turtlebot.
Recent Updates
Stay updated on Me132b Bug 2 Algorithm On Turtlebot's latest milestones.
Bug 2 Algorithm_1
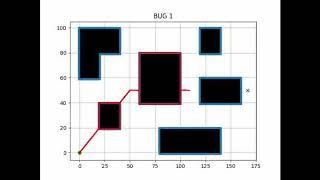
Bug2 - Path Planning Algorithm Explanation
Bug Algorithm Python - Bug 0, Bug 1 & Bug 2
Bug2 Motion Planning Algorithm
Bug-2 Algorithm
The Bug 2 Algorithm
Local Path Planning with obstacle avoidance using Bug 2 Algorithm
“Bug 2” algorithm | Gaezbo + ROS | Two wheeled mobile robot
Bug-2 Algorithm
How Robots Navigate Without a Map | Bug Algorithms Explained with TurtleBot in ROS & Gazebo
“Bug 2” algorithm | Gazebo + ROS | Two wheeled mobile robot
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: October 18, 2026
Future Outlook
For 2026, Me132b Bug 2 Algorithm On Turtlebot remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
The video represents the implementation of the Wherein we introduce and explore the operation of the Github github.com/KirillGordievich/bug_algorithms_gazebo. In this video, I dive into the fascinating world of map-free robot navigation using the Bug Call the line from the starting point to the goal the m-line 1) head toward goal on the m-line