Looking for the latest information on Mobile Robot Simulation? We've compiled comprehensive data, records, and insights about Mobile Robot Simulation.
Main Features
Explore the main sources for Mobile Robot Simulation.
Recent Updates
Stay updated on Mobile Robot Simulation's newest achievements.
ROS2- Modeling, Simulation, and Control of 4-Wheeled Mobile Robot in ROS2 (Iron Irwini) and Gazebo
Position Control of Differential Drive Mobile Robot - Complete Tutorial with Simulation Animation
ROS 2 URDF Tutorial: Build a Mobile Robot From Scratch in RViz
Lidar and Mobile Robot Simulation From Scratch in ROS2 Jazzy and Gazebo - ROS2 Jazzy Tutorials
2-Wheel Differential Drive Robot - Simulation and Control in ROS2 and Gazebo From Scratch
2 Complete simulation of a mobile robot with MATLAB: Background / Simulation
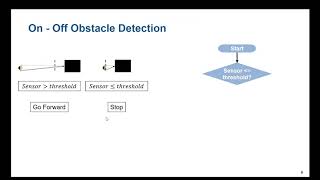
Mobile Robotics, Part 4: Designing Obstacle Detection Algorithms
Detailed and Correct Derivation of Kinematics Equations of Differential Drive Mobile Robot
Mobile Robotics, Part 1: Controlling Robot Motion
Simulating Mobile Robots with MATLAB and Simulink
Simulation of wheeled mobile robots
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 22, 2026
Future Outlook
For 2026, Mobile Robot Simulation remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
In this tutorial, I'll guide you through setting up and simulating a Learn how to train robots from scratch using mscsoftware.com/university/view_success_story.cfm?storyId=1 Toronto graduate student Sadath Malik, working under ... Playlist: youtube.com/playlist?list=PLdMuvhY3uTKsb2-ouIdMiEGuhIAxSrgIx (ROS 2 Tutorials) Build Your First ROS ... George Holmes, PhD student in Mechanical Engineering, presents a Learn how to design obstacle detection algorithms for a Sebastian Castro shows you how to get started with the i welcome you all in this lecture on