Looking for the latest information on Multiple Turtlebot? We've researched comprehensive data, records, and insights about Multiple Turtlebot.
Important Facts
Explore the main sources for Multiple Turtlebot.
Developments
Stay updated on Multiple Turtlebot's newest achievements.
Testing Multiple Turtlebot
TurtleBot 3 Burger Robot Build With Raspberry Pi
ROS 2: Multi-Robot Control with RQT Robot Steering | TurtleBot 3 | Gazebo
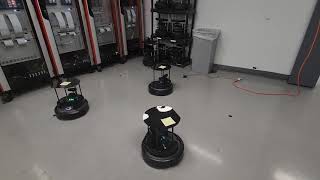
Simple Turtlebot Multi-Robot Formation
[Turtlebot Multi Systme]
Multiple turtlebot controller
TurtleBot navigating to multiple waypoints using proportional controller
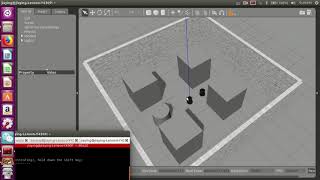
ROS turtlebot multiple obstacles
Multi Robot Map Merge Turtle Bot - How to Merge Map (Part - 1)
Multi Robot Simulation in TurtleBot House via Gazebo + RVIZ
Multi-Agent Systems Using Kobuki Turtlebots: Leader-Follower Premise
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: October 21, 2026
Final Thoughts
For 2026, Multiple Turtlebot remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Turtlebot4s maintain a fixed relative position during cycling, deployed by Saimai Lau. Turtle is derived from the Turtle robot, which was driven by the educational computer programming language Logo in 1967. A simple but powerful demonstration of Turtlebot3 - ROS2 Humble - Pytorch - yolov8.