Looking for the latest information on Path Tracking With Pid Controller? We've gathered comprehensive data, records, and insights about Path Tracking With Pid Controller.
Key Details
Explore the primary sources for Path Tracking With Pid Controller.
Recent Updates
Stay updated on Path Tracking With Pid Controller's latest milestones.
[PythonRobotics] Path tracking simulation with LQR steering control and PID speed control.
System Modeling: Path Tracking for Differential Steering Drive Autonomous Robots
Pneumatic Delta Robot: Path Tracking by PID Control
Mecanum Robot Trajectory Tracking with PID Control and ArUco Markers v1
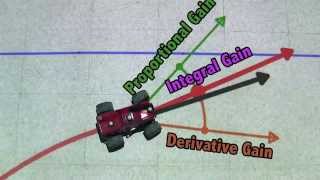
1. Driverless RC Car: Simple PID - Path Tracking
Homogeneous PID control design for trajectory tracking of a quadrotor autonomous vehicle
Mark 01 - Differential Robot #4 : Odometry and PID Controller
Trajectory Tracking for Autonomous Vehicles Using PID and MPC Controllers
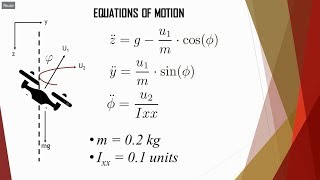
MATLAB & Simulink Tutorial: Quadrotor UAV Trajectory and Control Design (PID + Cascaded)
[PythonRobotics] Path tracking with rear wheel feedback steering control and PID speed control
Understanding PID Controllers
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 18, 2026
Conclusion
For 2026, Path Tracking With Pid Controller remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
[IEEE CSS Video Clip Contest 2015 Submission] This is a video introduction to controlling self-driving cars, specifically using ... Want to learn industrial automation? Go here: realpars.com ▷ Want to train your team in industrial automation? Go here: ... Code is here: github.com/AtsushiSakai/PythonRobotics/blob/master/PathTracking/lqr_steer_control/lqr_steer_control.py ... Localization: Uses four ArUco markers as reference points and one marker on the robot. - Computer Vision: A Rappo Full HD ... This is based on Artificial Intelligence for Robotics Course at Udacity. The project uses Arduino UNO and a speed sensor. Quadrotor unmanned aerial vehicles (UAVs) require precise and robust How to localize your robot using the wheel encoders and how to implement a Blog: mikelikesrobots.github.io/blog/understand-