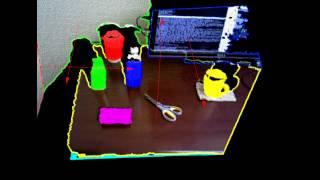
Cylinder Detection using RANSAC (ROS + Point Cloud Library)
Improving Perception in PCL
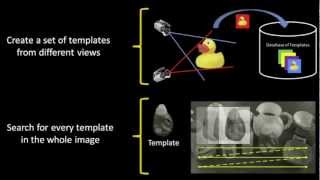
Object recognition and 6DOF pose estimation with PCL pointcloud and ROS
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 21, 2026
Summary
For 2026, Pcl Surface Detector remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Kinect + mrptで取得した点群から、 Playing around with PointCloud Libary This video shows the first version of the Voxel Grid (down sample), Registration (IA_Ransac, ICP), Moving Least Square, 4 datasets: the lab (0:00), the standard (0:43), chairs (1:58), and the sofa (3:23). Green boxes are segmented person clusters; red ... PS7: Point Cloud Processing for Cylindrical Object Testing the plane-fitting algorithm at Wean Hall, Carnegie Mellon University. The point cloud is obtained using the disparity map of ... Please see this video with the highest quality of resolution for best viewing.***** In this video, I demonstrate the use of the ... For more information please visit willowgarage.com. Real-time object recognition and 6DOF pose estimation with