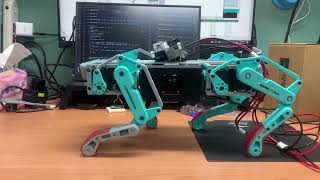
Looking for the latest information on Quadruped Robot Walking Simulation? We've compiled comprehensive data, records, and insights about Quadruped Robot Walking Simulation.
Main Features
Explore the primary sources for Quadruped Robot Walking Simulation.
Developments
Stay updated on Quadruped Robot Walking Simulation's latest milestones.
Learning to Walk in Minutes Using Massively Parallel Deep RL
Walking Simulation of a Quadruped Robot in Solidworks
Simulation: Two-leg standing and line walking of a quadruped robot.
Quadruped Robot Locomotion Training and Jogging Demonstration
Dynamic Walking Of a Quadruped Robot in 3D space
Dynamic Locomotion and Whole-Body Control for Quadrupedal Robots
Multi-body dynamics simulation of quadruped robot- Walking gait
Simple Quadruped Robot Simulation
Training a Quadruped Robot to Walk With Payload | Reinforcement Learning
Learning to Walk in the Real World in 1 Hour (No Simulator)
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Summary
For 2026, Quadruped Robot Walking Simulation remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This video features the model to be used in my In this tutorial I explain how to train a custom We present a training set-up that achieves fast policy generation for real-world In this leg design all the motors are concentrated on the shoulder joint. Hence the center of mass is near to the center of rotation, ... This controller is now being developed by Yoshiki Asakawa, an undergraduate student of Hiroshima University. This video demonstrates the jogging locomotion of a Code: github.com/paulyang1990/QuadrupedSim. This paper presents a framework which allows a