Our implementation of Real-time RRT* with multi-query support
Tube RRT*: Efficient Homotopic Path Planning for Swarm Robotics
pRRTC: GPU-Parallel RRT-Connect for Fast, Consistent, and Low-Cost Motion Planning
An anytime implementation of the RRT* algorithm
RRT* algorithm on a race car (270 degree turn)
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 15, 2026
Future Outlook
For 2026, Rrt Connect Avi remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
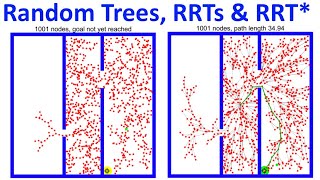
Rapidly-exploring Random Trees ( Rapidly Exploring Trees searching bidirectionally for a Implementation of the extend variant of the See the other videos in this series: youtube.com/playlist?list=PLn8PRpmsu08rLRGrnF-S6TyGrmcA2X7kg This video ... Lecture 24 of Intro to Robotics @ University of Houston. using ... A video for our RA-L 2025 paper, "AORRTC: Almost-Surely Asymptotically Optimal Planning with Recently, the concept of homotopic trajectory planning has emerged as a novel solution to navigation in large-scale obstacle ... Video supplement for "pRRTC: GPU-Parallel