Looking for the latest information on Rrt Rapidly Exploring Random Trees? We've gathered comprehensive data, records, and insights about Rrt Rapidly Exploring Random Trees.
Key Details
Explore the primary sources for Rrt Rapidly Exploring Random Trees.
History
Stay updated on Rrt Rapidly Exploring Random Trees's latest milestones.
Path Planning with A* and RRT | Autonomous Navigation, Part 4
A Review of Rapidly Exploring Random Tree Path Planning Algorithms
Kinodynamic Rapidly Exploring Random Trees (RRT) for Autonomous ISS Inspection
Rapidly-exploring Random Tree [RRT] Algorithm Implementation in Python | Robotics
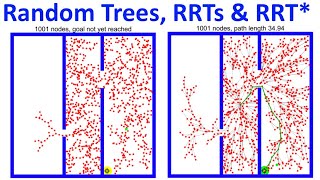
Rapidly Exploring Random Tree Algorithm (RRT)
[18] Rapidly Explore Random Trees RRT - MATLAB coding
Rapidly Exploring Random Trees (RRT) Applied to a Kinematic Car Model
Randomly Exploring Random Trees - RRt
Autonomous Exploration using Rapidly Exploring Random Trees (RRT)
RRT (Rapidly-Exploring Random Trees) C++
RRT* Algorithm: Optimal Path Planning for Complex Environments
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Future Outlook
For 2026, Rrt Rapidly Exploring Random Trees remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
VDEngineering ~~My Udemy Courses on Motion Planning / Navigation / Trajectory Planning: ... The algorithm can be found in section 5 of Chapter 10 in the Modern Robotics textbook by Frank Chongwoo Park and Kevin M. See the other videos in this series: youtube.com/playlist?list=PLn8PRpmsu08rLRGrnF-S6TyGrmcA2X7kg This video ... Path planning algorithms are robot navigation techniques that determine a robot'™s route from its beginning to its goal ... On this channel you will find video realted to course (see channel's playlist) Learn & enjoy and Don't forget to ! check ... This video briefly explains and demonstrates autonomous A C++ implementation of path planning algorithm