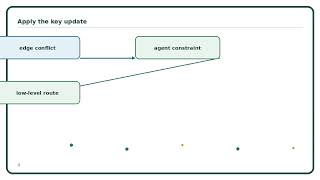
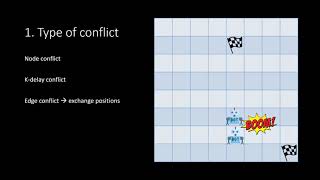
Overview to The Centralised Method For Solving Multi Agent Pathfinding Problems
Looking for the latest information on The Centralised Method For Solving Multi Agent Pathfinding Problems? We've gathered comprehensive data, records, and insights about The Centralised Method For Solving Multi Agent Pathfinding Problems.
Key Details
Explore the primary sources for The Centralised Method For Solving Multi Agent Pathfinding Problems.
Developments
Stay updated on The Centralised Method For Solving Multi Agent Pathfinding Problems's newest achievements.
Symmetry Breaking Constraints for Multi-Agent Pathfinding
Michal Opler: Solving Multiagent Path Finding on Highly Centralized Networks
Conflict-Based Search for Explainable Multi-Agent Path Finding
Subdivide MAPF problems with Independence Detection (ID)
Wang Xiaoyu - Multi Agent Path Finding
Multi Agent Systems Explained: How AI Agents & LLMs Work Together
Multi-Agent Path Finding (MAPF)
ICAPS 2020: Zhang et al. on Multi-Agent Path Finding with Mutex ...
Explainable Multi Agent Path Finding
Distributed Multi-agent Navigation Based on ORCA and MAPF solving
Oren Salzman: Multi-Agent Path Finding: New Analysis, Problem Variants and Algorithms
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Summary
For 2026, The Centralised Method For Solving Multi Agent Pathfinding Problems remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This talk aims to invite you to the forefront of MAPF research directly This is a re-recording of my invited talk at EurMAPF-25, ... Conflict Based Search is a staple, state-of-the-art MAPF Presented at the 2019 Amazon Research Awards Robotics Symposium. In this talk we describe recent progress in the area of ... J. Kottinger, S. Almagor, and M. Lahijanian, “Conflict-Based Search for Explainable Independence Detection (ID) is a simple Ready to become a certified watsonx AI Assistant Engineer? Register now and use code IBMTechYT20 for 20% off of your exam ... RBE 550: Motion Planning Project Proposal Presentation Team: Dheeraj Bhogisetty, Shiva Surya Lolla and Siyuan Huang ... ICAPS 2020 talk on the paper Han Zhang, Jiaoyang Li, Pavel Surynek, Sven Koenig, T. K. Satish Kumar. Short presentation of the paper: Shaull Almagor and Morteza Lahijanian, "Explainable Theta* for geometric path planning. ORCA for path following with collision avoidance. Ad-hoc deadlock detection mechanism. Talk by Oren Salzman in TAU CG seminar 24-Nov-2021.
The Centralised Method For Solving Multi Agent Pathfinding Problems.pdf
What is the most accurate information about The Centralised Method For Solving Multi Agent Pathfinding Problems?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about The Centralised Method For Solving Multi Agent Pathfinding Problems.
Why is The Centralised Method For Solving Multi Agent Pathfinding Problems trending right now?
Interest in The Centralised Method For Solving Multi Agent Pathfinding Problems has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for The Centralised Method For Solving Multi Agent Pathfinding Problems?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about The Centralised Method For Solving Multi Agent Pathfinding Problems updated?
We regularly update our database with the latest information, media, and analysis related to The Centralised Method For Solving Multi Agent Pathfinding Problems.