About to Trajectory Optimization For A Running Humanoid
Looking for the latest information on Trajectory Optimization For A Running Humanoid? We've researched comprehensive data, records, and insights about Trajectory Optimization For A Running Humanoid.
Core Information
Explore the primary sources for Trajectory Optimization For A Running Humanoid.
Developments
Stay updated on Trajectory Optimization For A Running Humanoid's newest achievements.
Tutorial: Gait and Trajectory Optimization for Legged Robots
Trajectory Optimization and Control of Rigid Body System Through Contact
Stabilizing a falling humanoid with hand contact
Trajectory optimization of robots through contact
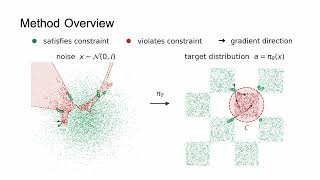
Safe Real-Time Policy Steering via Noise-Space Trajectory Optimization for Generative Policies
Locomotion Planning through a Hybrid Bayesian Trajectory Optimization
Safe trajectory optimization for whole-body motion of humanoids
Gait and Trajectory Optimization for Legged Systems through Phase-Based End-Effector Parameterizatio
Robust Humanoid Locomotion Using Trajectory Optimization and Sample-Efficient Learning
Robust Humanoid Locomotion Using Trajectory Optimization and Sample-Efficient Learning
Updated: Trajectory Optimization Through Contacts and Automatic Gait Discovery for Quadrupeds
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Future Outlook
For 2026, Trajectory Optimization For A Running Humanoid remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Final Project for MIT 6.832 - Underactuated Robotics. 6.8210 Underactuated Robotics Final Project In which we make a Preprint: arxiv.org/pdf/2211.12849.pdf Code: ... One of the essential aspects of Paper, video, open-source code, slides and more: awinkler.me Intro: 00:29 - Why Legged Robots? 01:15 - Context of ... Authors: Michael Posa, Russ Tedrake Title: The method shown performs real-time Supplemental video material for "Safe Real-Time Policy Steering via Noise-Space Publication by Tim Seyde, Jan Carius, Ruben Grandia, Farbod Farshidian, Marco Hutter Robotic Systems Lab, ETH Zurich ... Multi-task prioritized controllers generate complex behaviors for ICRA 2018 Spotlight Video Interactive Session Tue PM Pod H.2 Authors: Winkler, Alexander W.; Bellicoso, C. Dario; Hutter, Marco ... The main idea of this work is to use data from full-body simulation of
Trajectory Optimization For A Running Humanoid.pdf
What is the most accurate information about Trajectory Optimization For A Running Humanoid?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Trajectory Optimization For A Running Humanoid.
Why is Trajectory Optimization For A Running Humanoid trending right now?
Interest in Trajectory Optimization For A Running Humanoid has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Trajectory Optimization For A Running Humanoid?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Trajectory Optimization For A Running Humanoid updated?
We regularly update our database with the latest information, media, and analysis related to Trajectory Optimization For A Running Humanoid.