Background to Wiggle Pathfinding To Multiple Goals
Looking for the latest information on Wiggle Pathfinding To Multiple Goals? We've compiled comprehensive data, records, and insights about Wiggle Pathfinding To Multiple Goals.
Key Details
Explore the main sources for Wiggle Pathfinding To Multiple Goals.
History
Stay updated on Wiggle Pathfinding To Multiple Goals's newest achievements.
Multiple Instance Path Finding
HPlan 2021: A Hierarchical Approach to Multi-Agent Path Finding
Motion planning with multiple goals
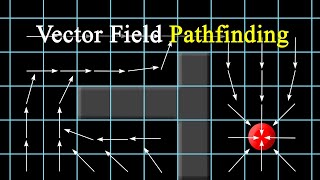
How do vector field Pathfinding algorithm work
X*: Anytime Multi-Agent Path Finding for Sparse Domains using Window-Based Iterative Repairs - Full
ICAPS 2017: Any-Angle Pathfinding For Multiple Agents Based On SIPP Algorithm
Pathfinding with multiple unit sizes and abilities.
Conflict-Based Search for Explainable Multi-Agent Path Finding
ICAPS 2020: Zhang et al. on Multi-Agent Path Finding with Mutex ...
Infallible Pathfinding in 3D
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Conclusion
For 2026, Wiggle Pathfinding To Multiple Goals remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
In this tutorial, Sidney Durant explains vector field In this video (4K ultra HD); we are a software to pre-calculate / pre-compute all of the possible paths from all ... Programmed over the span of two weeks in GameMaker: Studio for my current project Seven Saints. I do apologize in advance for ... This is a poster teaser talk for the paper "A Hierarchical Approach to In today's video, we will see how to create from scratch a vector field We present background and detailed overview of the Windowed Anytime Multiagent Planning Framework (WAMPF), a framework ... This video shows off how my AI code handles J. Kottinger, S. Almagor, and M. Lahijanian, “Conflict-Based Search for Explainable ICAPS 2020 talk on the paper Han Zhang, Jiaoyang Li, Pavel Surynek, Sven Koenig, T. K. Satish Kumar. The algorithm uses Dijkstra to find a path between tiles and uses divisions to check if a path exists. 0:05 - The world generation ...