Looking for the latest information on Apriltag Slam Using Factor Graph? We've gathered comprehensive data, records, and insights about Apriltag Slam Using Factor Graph.
Key Details
Explore the main sources for Apriltag Slam Using Factor Graph.
Developments
Stay updated on Apriltag Slam Using Factor Graph's newest achievements.
April Tag SLAM
Factor Graph - 5 Minutes with Cyrill
Factor Graphs + TagSLAM For Efficient Map and Pose Optimization
Factor-Graph SLAM with ArUco Markers on iPhone Data
JetHexa--AprilTag Recognition
AprilTag based pose estimation.
SLAM and Apriltag Detection
Attitude Control with Factor Graphs
MIT Robotics - Frank Dellaert - Factor Graphs for Perception and Action
Factor graph optimization for GNSS/INS integration: A comparison with the extended Kalman filter
TagSLAM: SLAM based on April Tags
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Summary
For 2026, Apriltag Slam Using Factor Graph remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
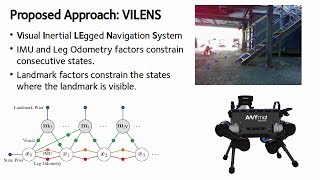
Implementation of an optimization based "Robust Legged Robot State Estimation This video provides some intuition around Pose How do robots really know where they are — not just guess? In this video, we dive deep into the world of This video was developed as an exercise to understand MIT - December 3, 2021 Frank Dellaert " By Weisong Wen, Tim Pfeifer, Xiwei Bai, Li-Ta Hsu TagSLAM is a ROS based package for simultaneous multi-camera localization and mapping (