Looking for the latest information on Cs686 8 Rrt Techniques? We've researched comprehensive data, records, and insights about Cs686 8 Rrt Techniques.
Important Facts
Explore the key sources for Cs686 8 Rrt Techniques.
History
Stay updated on Cs686 8 Rrt Techniques's latest milestones.
RRT* Algorithm Explained
RRT* algorithm on a race car (270 degree turn)
RRT* variants for solving differential games
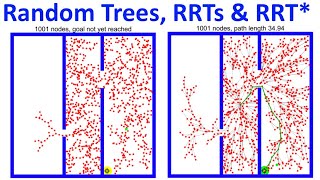
RRT, RRT* & Random Trees
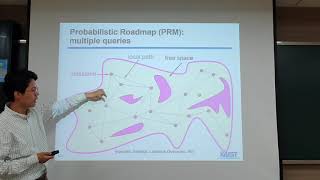
CS686: 7. Probabilistic Roadmaps
RRT* algorithm on a race car (180 degree turn)
RRT Algorithm with Kalman Uncertainty
RRT* algorithm illustrative example
RRT algorithm
[Figure 6(a)] Biased Target-tree* Algorithm with RRT* for Fast Parking Path Planning
COMS W4733 Lab 4: Bidirectional RRT (RRT Connect)
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 16, 2026
Final Thoughts
For 2026, Cs686 8 Rrt Techniques remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
I am happy to present this work on Real-time Recently, the concept of homotopic trajectory planning has emerged as a novel solution to navigation in large-scale obstacle ... A probabilistically-complete and probabilistically-sound algorithm based on the Lecture 24 of Intro to Robotics @ University of Houston. using ... This talks about probabilistic roadmap (PRM) Part of Project assignment of course Planning and Decision Making. Delft University of Technology Group 31: Georgios ... Bidirectional rapidly-exploring random tree.