Looking for the latest information on Fastslam? We've compiled comprehensive data, records, and insights about Fastslam.
Main Features
Explore the key sources for Fastslam.
Developments
Stay updated on Fastslam's newest achievements.
Simultaneous Localization and Mapping (SLAM): FastSLAM
FastSlam 1.0 with 100 particles and 150 obstacles
FastSLAM Implementation in Webots (Particle Filter + EKF)
Grid-based FastSLAM (loop closure)
FastSLAM 1.0
[PythonRobotics] A feature based SLAM example using FastSLAM 2.0.
SLAM Course - 13 - Grid-Based FastSLAM - Cyrill Stachniss
FastSLAM Loop Closure
Mapping a room using FastSLAM
FastSLAM Simulation Visualization – Particle Behavior and Trajectory Estimation
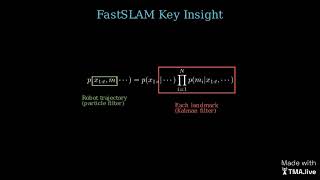
FastSLAM Algorithm - Factorized Solution to Simultaneous Localization and Mapping
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 17, 2026
Future Outlook
For 2026, Fastslam remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Recorded Lecture "Robot Mapping", Chapter: Weight that's it that was all the black magic involved in This video is part of the lecture series for the course Sensor Fusion. It describes how to solve the simultaneous localization and ... Matlab implementation of FastSlam1.0. The robot moves in a circular trajectory, in an area 60x60 m with 150 obstacles in it. Demonstrates an implementation of a grid-based This project is inspired by the Robot Mapping class taught by Dr. Cyrill Stachniss back in Fall 2013. The code should be ... Code is here: github.com/AtsushiSakai/PythonRobotics/blob/master/SLAM/FastSLAM2/fast_slam2.py Repository is here: ... Consider the video of the 2013/14 course as the audio quality is much better: ...