Introduction of Pathfinding Multiple Agent Stresstest
Looking for the latest information on Pathfinding Multiple Agent Stresstest? We've compiled comprehensive data, records, and insights about Pathfinding Multiple Agent Stresstest.
Important Facts
Explore the key sources for Pathfinding Multiple Agent Stresstest.
History
Stay updated on Pathfinding Multiple Agent Stresstest's latest milestones.
Upgrading Multi-Agent Pathfinding for the Real World
Conflict-Based Search for Explainable Multi-Agent Path Finding
Distributed Multi-agent Navigation Based on ORCA and MAPF solving
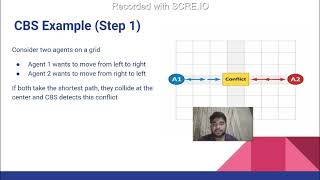
Conflict-Based Search (CBS) and Heuristics for Multi-Agent Path Finding
X*: Anytime Multi-Agent Path Finding for Sparse Domains using Window-Based Iterative Repairs - Full
Priority Inheritance with Backtracking for Iterative Multi-agent Path Finding
Multi-Agent Path Finding (MAPF) - Final Presentation
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: October 18, 2026
Summary
For 2026, Pathfinding Multiple Agent Stresstest remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This talk aims to invite you to the forefront of MAPF research directly This is a re-recording of my invited talk at EurMAPF-25, ... J. Kottinger, S. Almagor, and M. Lahijanian, “Conflict-Based Search for Explainable Theta* for geometric path planning. ORCA for path following with collision avoidance. Ad-hoc deadlock detection mechanism. We present background and detailed overview of the Windowed Anytime Keisuke Okumura, Manao Machida, Xavier Défago & Yasumasa Tamura. "Priority Inheritance with Backtracking for Iterative ... RBE 550: Motion Planning Project Proposal Presentation Team: Dheeraj Bhogisetty, Shiva Surya Lolla and Siyuan Huang ... Short presentation of the paper: Shaull Almagor and Morteza Lahijanian, "Explainable Proof of expandability and future scope of the project Project Github:- github.com/shlok377/AIPathFinder Contributors:- 1. Final Project Presentation RBE550: Motion Planning