Looking for the latest information on Pythonrobotics Graph Based Slam? We've compiled comprehensive data, records, and insights about Pythonrobotics Graph Based Slam.
Important Facts
Explore the primary sources for Pythonrobotics Graph Based Slam.
Recent Updates
Stay updated on Pythonrobotics Graph Based Slam's latest milestones.
[PythonRobotics] Graph based SLAM
Optimized Graph-based SLAM
[PythonRobotics] A feature based SLAM example using FastSLAM 1.0.
Understanding SLAM Using Pose Graph Optimization | Autonomous Navigation, Part 3
An implementation of Visual Graph-Based SLAM
Graph Based SLAM and Loop Closure
Wolfram Burgard, Giorgio Grisetti, and Cyrill Stachniss: Graph-based SLAM in 20 Minutes
Graph Based SLAM simulation LabVIEW ver
Tutorial on Graph Based SLAM G2O 论文分享 (A)
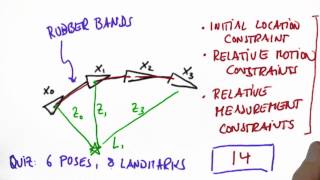
Graph SLAM Solution - Artificial Intelligence for Robotics
[PythonRobotics] A feature based SLAM example using FastSLAM 2.0.
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: October 17, 2026
Summary
For 2026, Pythonrobotics Graph Based Slam remains one of the most searched-for information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This video is part of an online course, Intro to Artificial Intelligence. the course here: ... Code is here: github.com/AtsushiSakai/ Shows introductory material relating to solving the Simultaneous Localization and Mapping ( This video provides some intuition around Pose This is an (offline) implementation of the Filtering methods the Extended Kalman Filter fail due to quadratic complexity in state size. This is a short video lecture by Wolfram, Giorgio, and Cyrill explaining 파이썬 소스코드 LabVIEW 버전으로 컨버전 중. 실제 로봇에 적용전에 시뮬레이션으로 동작확인 및 코드 분석 중... ref) ...