How to set robot initial pose after AMCL launches in ROS navigation stack
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 19, 2026
Final Thoughts
For 2026, Ros Navigation Stack remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
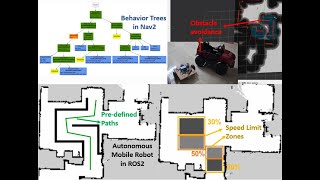
This ROS2 Nav2 crash course will get you started with the Companion blog post coming soon 💻️ GitHub code at the end of this tutorial ... UPDATE: If you're on humble or newer, please note that "params_file" has changed to "slam_params_file". SLAM is an important ... Video describing my work in implementing the standard In This video, I have explained about This video is about the navigation2 in ros2. We will cover 1. Overview of Navigation2 2. Understanding the concept of Behavior ... Here is the video where i have implemented Get FREE Robotics & AI Resources (Guide, Textbooks, Courses, Resume Template, Code & Discounts) – Sign up via the pop-up ... This video demonstrates a simple pick and drop tasks in an indoor environment. When you run laser_amcl_demo.launch with a map in