Looking for the latest information on Stereo Visual Slam? We've compiled comprehensive data, records, and insights about Stereo Visual Slam.
Main Features
Explore the key sources for Stereo Visual Slam.
Recent Updates
Stay updated on Stereo Visual Slam's latest milestones.
Stereo Visual SLAM
Monocular SLAM with ORB-SLAM3 and Raspberry Pi Camera Module V2
Apple Vision Pro from Scratch (Visual SLAM)
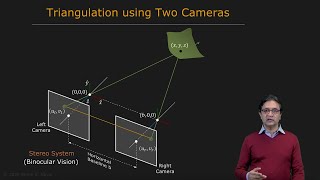
Distance Measurement With a Stereo Camera using Python and OpenCV
The Reality of Visual Odometry: What They Don't Tell You
Stereo Camera Semantic Slam in Dynamic Environment
Stereo Visual SLAM Built From Scratch
Simple Stereo | Camera Calibration
vSLAM 6DoF
SLAM using Stereo Vision on LAGR Robot
Stereo VINS SLAM algorithm implementation with IMU integration
Full Guide
Data is compiled from public records and verified media reports.
Last Updated: October 20, 2026
Conclusion
For 2026, Stereo Visual Slam remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Daniel Cremers, Technical University Munich This work was developed by the Hardware and Embedded Systems Lab's SAILoR Research Group in NTU, Singapore, with a ... ORB-SLAM3 runs on a remote laptop. The free space of the occupancy map is drawn using the Bresenham's line algorithm, ... I built a clone of the Apple Vision Pro OS to better learn how it works under the hood. In this video, I build a This work has been done in the context of a project at the University of Karlsruhe. Two cameras are calibrated and a disparity map ... Objects are labeled with movability. Blue: High movability, i.e. person Red: Mideum movability, i.e. chair Green: Low movability, ...