Looking for the latest information on Test Dwa Navigation? We've gathered comprehensive data, records, and insights about Test Dwa Navigation.
Main Features
Explore the key sources for Test Dwa Navigation.
Latest News
Stay updated on Test Dwa Navigation's latest milestones.
Mobile Robot Navigation Performance Test
navigation using dwa local planner(turtlebot 3)
Navigation indoor using DWA planner and move_base,and AMCL for locallization.
Dynamic Window Approach for local navigation test map2
[04] - Custom Nav2 Global Planner and DWA-Based Controller Experiment | ROS 2 Mobile Robot
Autonomous Navigation Test - HOME to Destination A
ONSAP Navigation Simulation Test Exersise II Fleet Vessel II Sailor 360
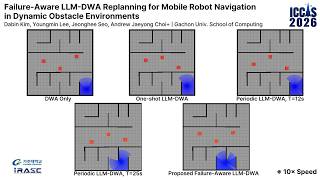
Failure-Aware LLM-DWA Replanning for Mobile Robot Navigation in Dynamic Obstacle Environments
Autonomous Guided Vehicle amcl navfn dwa - navigation stack experiment
Autonomous Guided Vehicle Test 10 ekf g navfn l dwa- Navigation Stack Experiment
Test #3 Local Planner DWA
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 22, 2026
Future Outlook
For 2026, Test Dwa Navigation remains one of the most talked-about information profiles. Check back for the latest updates.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Local collision avoidance is a primary task for mobile robots The aim of this video is to show the performace of the diferent global planners implement in ros using the same local planner. first map server load the occupancy grid map and give the robot initail pose to start localization using amcl and while moving robot ... This video demonstrates the experimental implementation of a custom Nav2 ICCAS 2026 | Experimental Demonstration This video demonstrates a failure-aware LLM- Autonomous Guided Vehicle amcl navfn