Looking for the latest information on Grasp Synthesis Using Active Vision? We've researched comprehensive data, records, and insights about Grasp Synthesis Using Active Vision.
Core Information
Explore the main sources for Grasp Synthesis Using Active Vision.
Developments
Stay updated on Grasp Synthesis Using Active Vision's latest milestones.
Closing the Loop for Robotic Grasping: A Real-time, Generative Grasp Synthesis Approach
D-Grasp: Physically Plausible Dynamic Grasp Synthesis for Hand-Object Interactions
Grasping unknown objects using active vision
More Than a Feeling: Learning to Grasp and Regrasp using Vision and Touch
One shot grasp Synthesis
Vision-based grasping algorithm
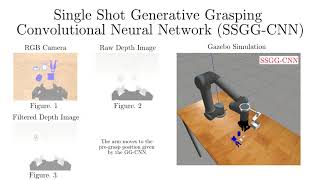
Single Shot Generative Grasping Convolutional Neural Network
Demonstration of continuous 3D object recognition and grasp synthesis.
Grasping Using High-Speed Visual Feedback
Dynamic Grasping Using High-speed Visual Feedback
Continuum Robot based Grasp Synthesis and Object Manipulation
Expert Insights
Data is compiled from public records and verified media reports.
Last Updated: October 21, 2026
Summary
For 2026, Grasp Synthesis Using Active Vision remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
For more information about this project please visit our lab website: wp.wpi.edu/merlab/ Video demo for ICRA2023 paper "Instance-wise Paper to appear at RSS 2018. arxiv.org/abs/1804.05172 Code available at github.com/dougsm/ggcnn This paper ... This video presents simulation and experimental results of a novel More Than a Feeling: Learning to developed by HYU Biorobotics Lab (Minchang Sung) Code is provided at: github.com/lar-deeufba/ssggcnn_ur5_grasping This paper proposes a two-step cascaded system Lifelong 3D Object Recognition and In most conventional manipulation systems, changes in the environment cannot be observed in real time because the