Looking for the latest information on Multi Robot Exploration Tool? We've compiled comprehensive data, records, and insights about Multi Robot Exploration Tool.
Important Facts
Explore the primary sources for Multi Robot Exploration Tool.
Latest News
Stay updated on Multi Robot Exploration Tool's newest achievements.
Review of multi-robot exploration || How can multiple robots map together an environment
[IEEE TVT] Multi-Robot Cooperative Exploration via Deep Reinforcement Learning
Autonomous Exploration and Science with Multi-Robot Team | ARISE Project
A fully autonomous aerial multi-robot system for power tower inspection tasks
Distributed Multi Robot Exploration
Multi-Robot Patrolling Task - Simulation in Stage/ROS
Energy-Aware Multi-Robot Exploration
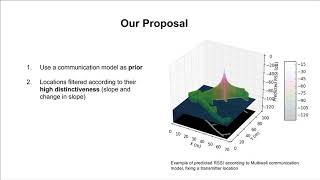
MRS2017 Multirobot exploration for building communication maps with prior from communication models
Sampling-based multi-robot exploration
Distributed Multi-robot Exploration and Mapping
[IROS'26] Scalable Multi-Robot Informative Path Planning for Target Mapping via Deep RL
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 20, 2026
Conclusion
For 2026, Multi Robot Exploration Tool remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Paper Accepted to IROS 2023. Authors: Ehsan Latif and Prof. Ramviyas Parasuraman School of Computing, University of Georgia ... Heriot-Watt University School of Mathematical and Computer Sciences Master in This work is published in IEEE Transactions on Vehicular Technology. For more details, please check: ... In the ARISE project, the FZI Research Center for Information Technology and its international partners ETH Zurich, University of ... ABSTRACT: Inspection of power line infrastructures must be periodically conducted by electric companies in order to ensure ... Lakeside Labs and NES institute of the Alpen-Adria-Universität are working on autonomous Micha Rappaport about the coordination of mobile Extension of the ICRA2017 paper on Zhi Yan, Nicolas Jouandeau, and Arab Ali Cherif. Sampling-based My focused talk on MRIPP at IROS 2026 in Pittsburgh, PA.