Background on Ncs 23 Feedback Linearization Motivation And Basic Concept
Looking for the latest information on Ncs 23 Feedback Linearization Motivation And Basic Concept? We've gathered comprehensive data, records, and insights about Ncs 23 Feedback Linearization Motivation And Basic Concept.
Key Details
Explore the key sources for Ncs 23 Feedback Linearization Motivation And Basic Concept.
Recent Updates
Stay updated on Ncs 23 Feedback Linearization Motivation And Basic Concept's newest achievements.
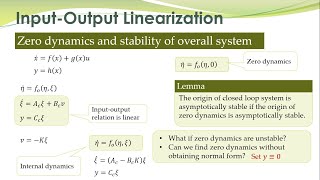
NCS - 29 - Internal dynamics, zero dynamics, and example of input-output linearization
Easy Introduction to Feedback Linearization - Control Engineering Tutorials
NCS - 27 - Full state linearization when rho is less than n
Feedback Linearization | Input-Output Linearization(Cont.) | Nonlinear Control Systems
Lec14 - 03 (Feedback Linearization)
Motion Constraints and Feedback Linearization (Lectures on Regression and Control)
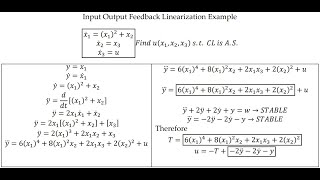
input output feedback linearization
Legged Robotics 23: Walker with partial feedback linearization (Spring 2021)
NCS - 08 - Jacobian linearization and near equilibrium point behavior of nonlinear systems
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: October 21, 2026
Future Outlook
For 2026, Ncs 23 Feedback Linearization Motivation And Basic Concept remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
Topics covered: 00:00 Introduction 01:33 Vector Field 01:54 Lie Derivative 03:07 Relative Degree of Output 08:28 This lecture explains two important control problems, that is, the stabilization problem and the tracking problem. This lecture talks about internal dynamics and stability of internal dynamics. To study the stability of internal dynamics, the The lecture demonstrates the full state This lecture presents a general discussion on full state Edit : the second term in x1(dot) is actually ([2+(x_3)^2]/[1+(x_3)^2])*u. Sorry for the mistake! Topics Covered: 00:00 ... Our question today is what I see can we always do that you know whose final transformation Explore the essentials of motion constraints such as nonholonomic dynamics and git hub link: github.com/ArtunSel/vid-062-input-output- The qualitative behavior of nonlinear systems near an equilibrium point can be described with the help of Jacobian
Ncs 23 Feedback Linearization Motivation And Basic Concept.pdf
What is the most accurate information about Ncs 23 Feedback Linearization Motivation And Basic Concept?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Ncs 23 Feedback Linearization Motivation And Basic Concept.
Why is Ncs 23 Feedback Linearization Motivation And Basic Concept trending right now?
Interest in Ncs 23 Feedback Linearization Motivation And Basic Concept has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Ncs 23 Feedback Linearization Motivation And Basic Concept?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Ncs 23 Feedback Linearization Motivation And Basic Concept updated?
We regularly update our database with the latest information, media, and analysis related to Ncs 23 Feedback Linearization Motivation And Basic Concept.