Overview to Single Query Path Planning Using Sample Efficient Probability Informed Trees
Looking for the latest information on Single Query Path Planning Using Sample Efficient Probability Informed Trees? We've researched comprehensive data, records, and insights about Single Query Path Planning Using Sample Efficient Probability Informed Trees.
Core Information
Explore the primary sources for Single Query Path Planning Using Sample Efficient Probability Informed Trees.
Developments
Stay updated on Single Query Path Planning Using Sample Efficient Probability Informed Trees's newest achievements.
Modern Robotics, Chapter 10.5: Sampling Methods for Motion Planning (Part 1 of 2)
TIGRIS: An Informed Sampling-based Algorithm for Informative Path Planning
The Easiest MAPF Algorithm: Prioritised Planning
A Single-Query Manipulation Planner
[PythonRobotics] Rapidly Randomized Tree (RRT) path planning sample
Bit*(Batch Informed Trees) with dynamic Obstacles(Anytime)
Path Planning Using PRM and RRT
A Review of Rapidly Exploring Random Tree Path Planning Algorithms
AM-RRT*: Informed Sampling-based Planning with Assisting Metric (ICRA 2021)
Decision Tree Analysis - Key Concepts in Project Management
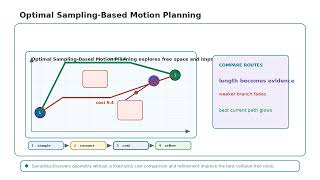
Optimal Sampling-Based Motion Planning
Deep Dive
Data is compiled from public records and verified media reports.
Last Updated: October 16, 2026
Final Thoughts
For 2026, Single Query Path Planning Using Sample Efficient Probability Informed Trees remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.
Summary
This video is our virtual presentation appearing at ICRA 2021 on our This video shows an improvement to the popular RRT* A video for our IJRR 2022 paper, "Adaptively A video for our ICRA 2020 paper, "Adaptively This is a video supplement to the book "Modern Robotics: Mechanics, Paper published in IEEE Robotics and Automation Letters, 2016 Preprint available at: arxiv.org/abs/1509.00600 In ... Code is here: github.com/AtsushiSakai/PythonRobotics/blob/master/ Accompanying video for ICRA 2021 paper ( arxiv.org/pdf/2010.14693.pdf) on our RT-RRT* extension for real-time
Single Query Path Planning Using Sample Efficient Probability Informed Trees.pdf
What is the most accurate information about Single Query Path Planning Using Sample Efficient Probability Informed Trees?
Our platform aggregates the most comprehensive and up-to-date insights, ensuring you get relevant details about Single Query Path Planning Using Sample Efficient Probability Informed Trees.
Why is Single Query Path Planning Using Sample Efficient Probability Informed Trees trending right now?
Interest in Single Query Path Planning Using Sample Efficient Probability Informed Trees has surged recently as more people seek reliable resources, related media, and detailed analysis.
Where can I find related media and updates for Single Query Path Planning Using Sample Efficient Probability Informed Trees?
You can explore extensive galleries, video summaries, and related content directly on this page.
How often is the content about Single Query Path Planning Using Sample Efficient Probability Informed Trees updated?
We regularly update our database with the latest information, media, and analysis related to Single Query Path Planning Using Sample Efficient Probability Informed Trees.